Rotating-reference-frame display
The rotating-reference-frame (RRF) view shows the slow envelope of a fast transverse-field precession. A run at 2 T precesses at ~271 MHz — about 2000 cycles across an 8 μs window — so the raw FB-asymmetry plot is a solid band that tells you nothing about how the signal relaxes. Demodulating into a frame rotating at a frequency \(\nu_0\) near the line leaves only what is slow: the relaxation envelope, and a beat at the offset \(\delta\nu = \nu - \nu_0\) if \(\nu_0\) is deliberately detuned. RRF display is standard practice for vortex-lattice and Knight-shift work at high field.
This page describes the filtered display of a single forward–backward asymmetry, available under Options → Advanced → Rotating reference frame. When a grouping measures both transverse projections — the \(P_x\) and \(P_y\) of vector-polarisation mode — the frame is reached exactly instead, bin by bin and without a filter, and the result can be fitted: see Rotating-frame projection. The filtered controls are not offered for such groupings.
The controls live in a row above the time-domain plot and appear only on the FB Asymmetry representation: an enable box, the frame frequency \(\nu_0\) (entered in MHz or Gauss — the two are equivalent through \(\nu = (\gamma_\mu/2\pi)B\)), a frame phase, the low-pass bandwidth, and the displayed component. When you first enable it, \(\nu_0\) is seeded from the run’s field metadata; type over it freely. The plot carries a frame badge (“frame: ν₀ = … MHz”) so exported figures remain self-describing, and the frame travels with exported data too. With several runs overlaid, the one frame applies to all of them — comparing envelopes across a temperature series at fixed field is the natural workflow.
What the transform does
The measured asymmetry \(A(t) = a(t)\cos(2\pi\nu t + \phi_d)\) is multiplied by the complex carrier \(2e^{-i(2\pi\nu_0 t + \phi)}\). The product contains the rotating-frame signal at \(\delta\nu\) and an image at \(\nu + \nu_0\), which a low-pass filter (a Blackman windowed-sinc FIR, stopband below −74 dB) removes. What remains is complex:
In-phase (Re) — the envelope, when the frame phase matches the data. The default view.
Quadrature (Im) — zero when the phase matches; signal leaking here diagnoses a phase error (or a frequency offset, which rotates the signal between the two components at \(\delta\nu\)).
Magnitude — the phase-free envelope \(|a(t)|\). Convenient, but noise-biased upward where the signal is comparable to its error bars (a non-Gaussian magnitude distribution), so treat near-zero magnitude qualitatively.
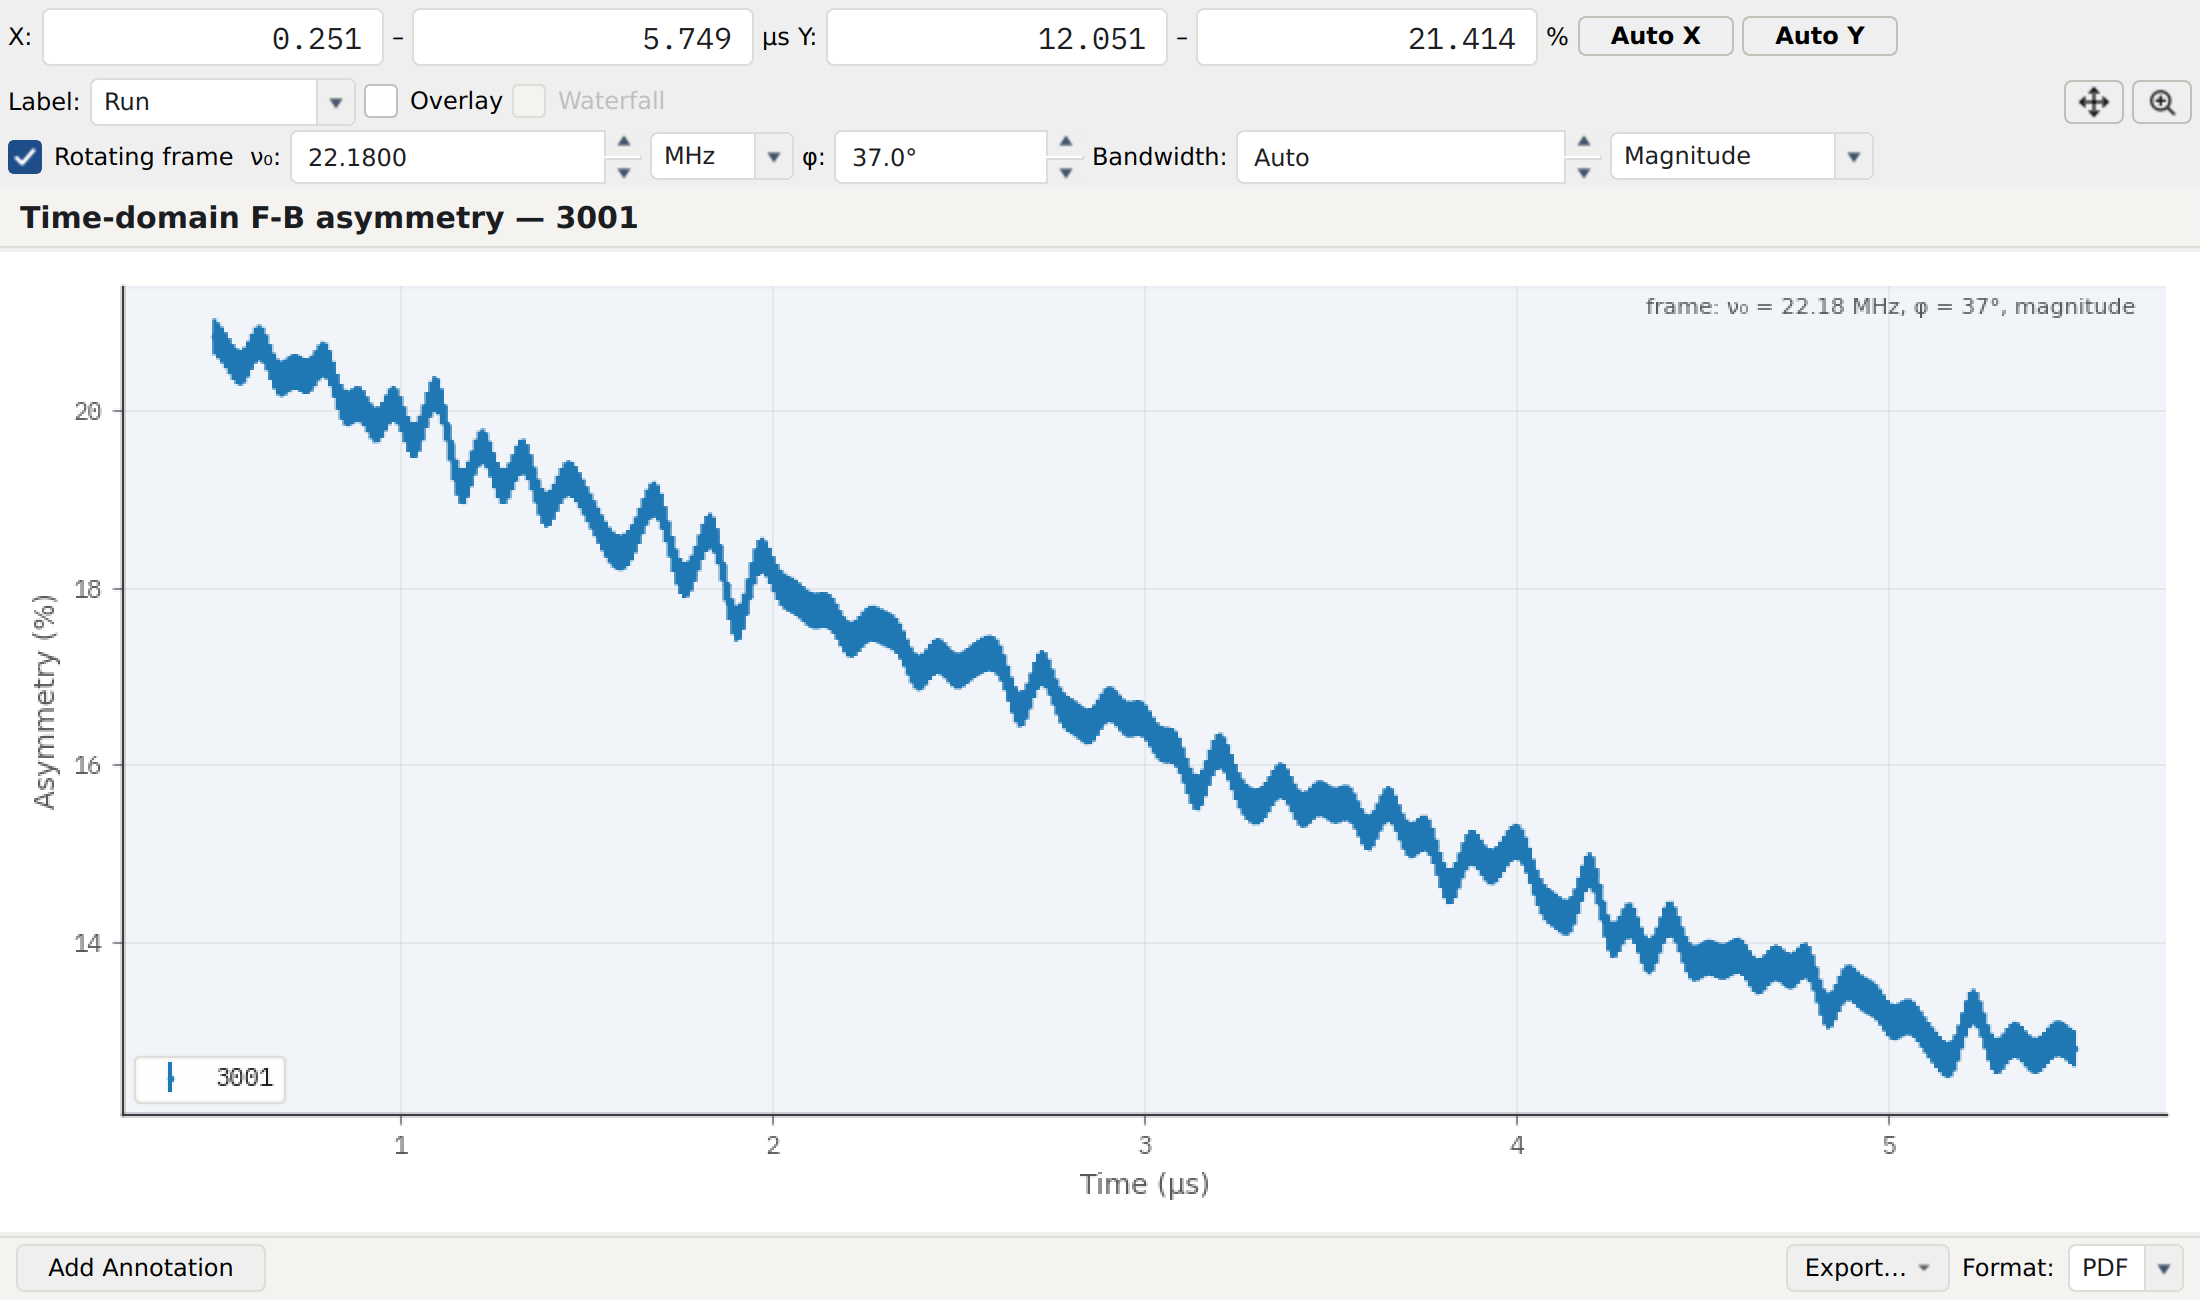
Magnitude of a synthetic EuO signal at 30 K, with a detuned frame and shared real/imaginary noise included in each error bar.
The bandwidth is the single-sided filter cutoff. Auto picks \(\nu_0/2\), reduced automatically when coarse binning folds the image back into the displayed band (an aliasing trap that affects data binned close to the Nyquist rate of the precession). Narrower bandwidth = smoother envelope but slower response; anything genuinely oscillating faster than the cutoff — including a large deliberate detuning beat — is filtered away with the image, so keep the bandwidth comfortably above \(|\delta\nu|\).
Magnitude errors
Both quadratures use the same scalar observations. For supplied independent input errors \(e_j\), carrier phase \(\theta_j=2\pi\nu_0t_j+\phi\), and actual normalised filter weights \(w_{ij}\), the same-bin covariance is
The weights include the finite-input mask and coverage normalisation used for the values and marginal variances. The covariance is signed. For \(r=\sqrt{R^2+I^2}>0\), first-order propagation [3] gives
An identity filter therefore takes a scalar input \(10\pm1\) to magnitude \(20\pm2\), independently of carrier phase. Percent inputs retain percent values and standard errors; covariance has squared percent units. Fractional inputs retain the corresponding fractional units.
These errors are conditional on the supplied scalar input-noise model. Correlations already present through estimated backgrounds or other reduction steps cannot be reconstructed from marginal input errors alone. Filtering also correlates output bins; same-bin covariance does not define a joint likelihood. At low signal-to-noise, magnitude remains biased and first-order errors are unreliable. At vanishing magnitude the display uses \(\sqrt{[\operatorname{var}(R)+\operatorname{var}(I)]/2}\) as a finite error-bar fallback, not a confidence interval. Asymmetry also checks for a materially negative propagated magnitude variance and raises an invariant error; only cancellation within floating-point accumulation roundoff is clipped to zero. Zero-noise model overlays retain exactly zero errors.
When to use it — and when not to. Use the RRF view to look: to see whether a high-field signal relaxes exponentially or Gaussian-like, to spot beats from closely-spaced lines (two frequencies \(\delta\) apart show up as an envelope oscillating at \(\delta\)), and to make figures where the physics is the envelope, not the carrier.
Do not fit the demodulated curve. The low-pass filter correlates neighbouring points over the filter support (the drawn error bars are conditional per-point errors, but the points are far from independent) and distorts lineshapes at the bandwidth scale; a χ² fit of the displayed curve gives wrong parameters and wrong uncertainties. The textbook is explicit that the RRF transform is a visualisation tool rather than a fit preprocessor [1]. Quantitative results come from fitting the raw data — which the fit panel always does, whatever the display shows. For working in rotating-frame numbers there, the core provides a frequency-offset fit using the raw data with the model’s precession frequencies offset by \(\nu_0\), so the fitted frequency reads as the small offset \(\delta\nu\) while the statistics remain those of the laboratory observations. The fitted curve drawn over an RRF display is demodulated through the same pipeline as the data, so the overlay always remains comparable.
A high-field caveat: at fields of several tesla, the geometric phases of the individual detectors span the full circle, and an asymmetry built by summing many detectors into one forward and one backward group can wash the precession line out almost completely. If the RRF view of a high-field run shows nothing, inspect a single near-opposite detector pair first — the proper multi-detector treatment (mapping all detectors onto one quadrature pair before the frame rotation [2]) is not yet implemented.
Compared with other programs
The core comparison API (method="wimda") uses real-cosine demodulation,
running box smoothing, and linearly averaged scaled standard errors. Its name
alone does not establish numerical agreement with WiMDA 1.326.
The FIR display instead
retains both quadratures and their shared-noise covariance. Independent identity
and measured linear-response checks establish its uncertainty propagation;
they do not establish numerical agreement with another program’s estimator.
musrfit 1.12.1 offers scalar asymmetry RRF preparation and packing through its RRF fit types. In Mantid, RRFMuon v1 (documentation associated with the 6.16 development snapshot) rotates two supplied components rather than constructing FIR quadratures from a scalar observation. Neither operation supplies a verified numerical covariance oracle for this FIR. No new native-program error agreement is asserted. WiMDA’s published description is given by F. L. Pratt, Physica B 289–290, 710 (2000), doi:10.1016/S0921-4526(00)00328-8.